Engineering Portfolio
I am a third-year Electrical Engineering student, building the habit of documenting the work, not just finishing the assignment.
PID Self-Balancing Robot
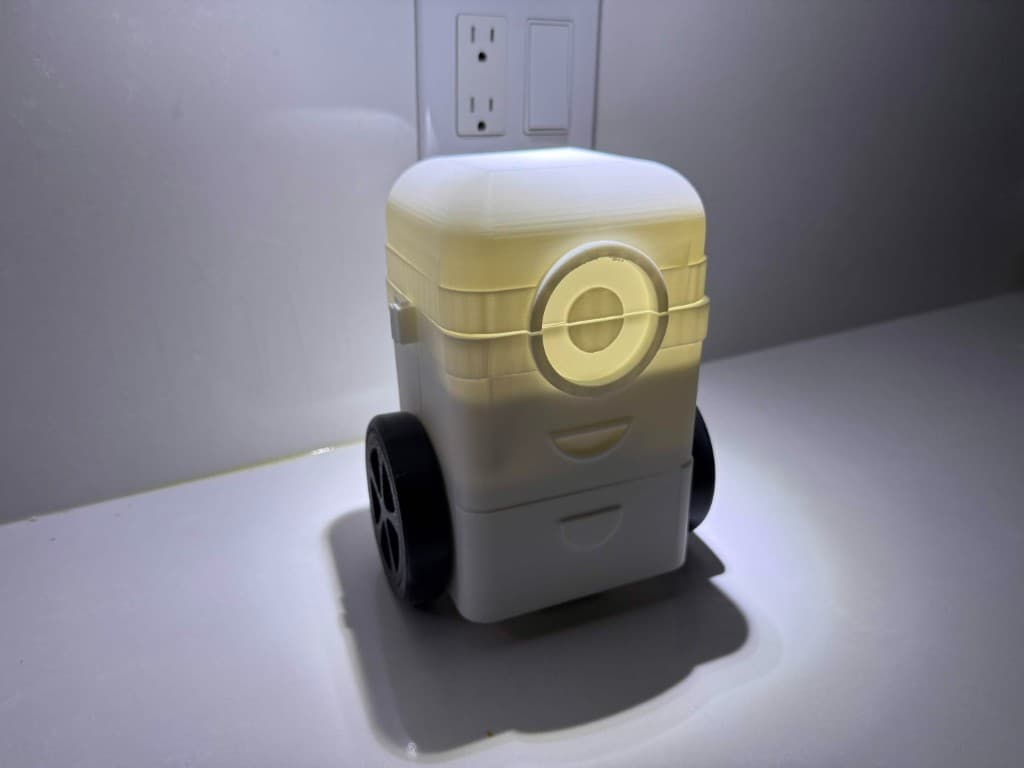
A two-wheel robot that stays upright with a PID feedback loop on an ESP32. I designed the custom PCB in KiCad, modeled and 3D-printed the chassis in Fusion 360, then brought the sensing, drive, and power stack up on the board until it balanced.
PID · KiCad · Fusion 360